GEWU DOCUMENTATION
GW-LS-RA1 60GHz Radar Level Sensor Guide
Compact, low-power and accurate non-contact water-level sensor. Learn the product capabilities, first-use steps and support options.
What should I know about GW-LS-RA1 60GHz Radar Level Sensor Guide?
Compact, low-power and accurate non-contact water-level sensor. Learn the product capabilities, first-use steps and support options.
| Version | Update Content | Date |
|---|---|---|
| V1.0 | Initial version | 2021‑03‑10 |
| V1.1 | 1. Optimized product model and mechanical structure; 2. Adjusted partial registers | 2025‑02‑28 |
1. Product Overview
The GW‑LS‑RA1 is a low‑power, high‑accuracy radar level gauge featuring ultra‑compact form factor and wide power‑supply range. With highly‑integrated design, it incorporates a millimeter‑wave radar and high‑gain horn antenna. Its overall ingress protection rating reaches IP67, making it suitable for field operating environments.
Equipped with an RS485 interface, the sensor supports standard Modbus protocol, and custom non‑standard protocols are available upon request. It can be applied to water conservancy & hydrology, sewage treatment, smart agriculture, object detection and many other scenarios.
2. Technical Specifications
Basic Parameters
| Item | Parameter | Remarks |
|---|---|---|
| Product Model | GW‑LS‑RA1 | |
| Supply Voltage | 7~28 VDC | |
| Operating Current | Average: 18 mA; Peak: 40 mA | |
| Ingress Protection | IP67 | |
| Overall Dimension | Φ54 × 60 mm | |
| Operating Temperature | -40~80 ℃ | |
| Operating Humidity | 0~100 % RH (non‑condensing) | |
| Zero Reference Line | Bottom of housing serves as zero‑position line |
Measurement Parameters
| Item | Parameter | Remarks |
|---|---|---|
| Measuring Range | 0.25‑10 m | Default dead‑zone: 0.25 m |
| Measurement Accuracy | ±5 mm | Measured on hard metallic reflecting surface |
| Radar Frequency | 60 GHz | |
| Antenna Beam Angle | 20° |
Communication Parameters
| Item | Parameter | Remarks |
|---|---|---|
| Physical Interface | RS485 | Baud rate: 9600 |
| Communication Protocol | MODBUS | Custom non‑standard protocols supported |
3. Power‑Supply Instructions
The device accepts input voltage from 7 V to 28 VDC and supports common DC power sources. A linear power supply is implemented internally; operating current is independent of supply voltage. Lower supply voltage yields lower overall power consumption.
For battery‑powered low‑power applications, it is recommended that the main controller controls device power‑on and cuts off module power after data acquisition to reduce total power consumption.
4. Operating Characteristics
Factory‑default parameters are configured for static level measurement and intended for scenarios with slowly‑changing target positions. When the target position changes abruptly, a certain time is required for output to synchronize with the latest position. Faster response can be achieved by modifying configuration parameters, which must be specified before shipment. Higher response speed will degrade measurement accuracy to some extent.
The device responds to Modbus commands immediately after power‑on; nevertheless internal radar data requires time to stabilize with a typical settling time of 5 seconds. For main controllers with low‑power logic, read radar data 5 seconds after power‑on to obtain valid readings.
By default the radar is tuned for slowly‑varying measurands such as water level. When target distance changes abruptly — for example when the radar is re‑oriented from ground toward ceiling or an object is placed beneath the radar — internal algorithms require considerably longer time (typically 30 seconds) to lock onto the new level value, much longer than the power‑on settling time. During testing, power‑cycling the device enables fast acquisition of valid readings after changing target conditions.
For applications requiring fast response to rapidly‑moving targets, notify us prior to shipment and negotiate response‑time requirements.
The unit internally evaluates radar echo strength. Level readings are discarded when echo strength falls below the configured threshold. Insufficient echo strength rarely occurs under normal operating conditions. The main controller may obtain real‑time echo‑strength values via Modbus for on‑site installation diagnosis.
Raw radar output represents empty‑height: distance from mounting point to target object. The device can output raw empty‑height or calculated level value. After writing the mounting reference value to the level register, output equals reference value minus empty‑height, i.e. the level value.
Output level values are always non‑negative:
- When reference value = 0: raw empty‑height is output directly.
- When reference value > empty‑height: output = reference value − empty‑height.
- When reference value < empty‑height: output = 0.
5. Protocol Description
Factory communication settings: baud rate 9600, 8 data bits, 1 stop bit, no parity; Modbus‑RTU protocol. Custom non‑standard protocols can be implemented for drop‑in replacement without modifying main‑controller logic.
5.1 Device Address
- Default device address: 1; configurable via commands.
- If the device address is forgotten, read data using address 0 to identify the actual address.
- When using address 0, ensure only one device is connected on the bus.
5.2 Register Map
| Parameter | Register Address | Data Type | Function Code | Description | Default Value |
|---|---|---|---|---|---|
| Level Data | 0x0000 | uint16 (Read‑Only) | 03 | Unit: mm | 0 |
| Device Address | 0x03E8 | uint16 (Read‑Write) | 03/06 | 1‑254 | 1 |
| Lower Range Limit | 0x001E | uint16 (Read‑Write) | 03/16 | ||
| Upper Range Limit | 0x001F | uint16 (Read‑Write) | 03/16 | ||
| Internal Zero Point | 0x002E | uint16 (Read‑Only) | 03 | Unit: mm | |
| Target Value | 0x002F | uint16 (Read‑Write) | 03/06 | Unit: mm | |
| Reference Setting | 0x0030 | uint16 (Read‑Write) | 03/06 | Unit: mm | 0 |
5.3 Communication Examples
Read Level Data (level value: 2000 mm)
| Transmit | 01 03 00 00 00 01 84 0A |
|---|---|
| Response | 01 03 02 07 D0 BB E8 |
Modify Device Address (from 01 to 02)
| Transmit | 01 06 03 E8 00 02 88 7B |
|---|---|
| Response | 01 06 03 E8 00 02 88 7B |
5.4 Parameter‑Configuration Example
You may view data and configure parameters with any serial‑port debugging tool using commands described in preceding sections. Operation via the visual tool Gewu Online Tool is recommended; no deep understanding of underlying Modbus frame format is required.
- Select official template: GW‑LS‑RA1 Radar Water‑Level Gauge.
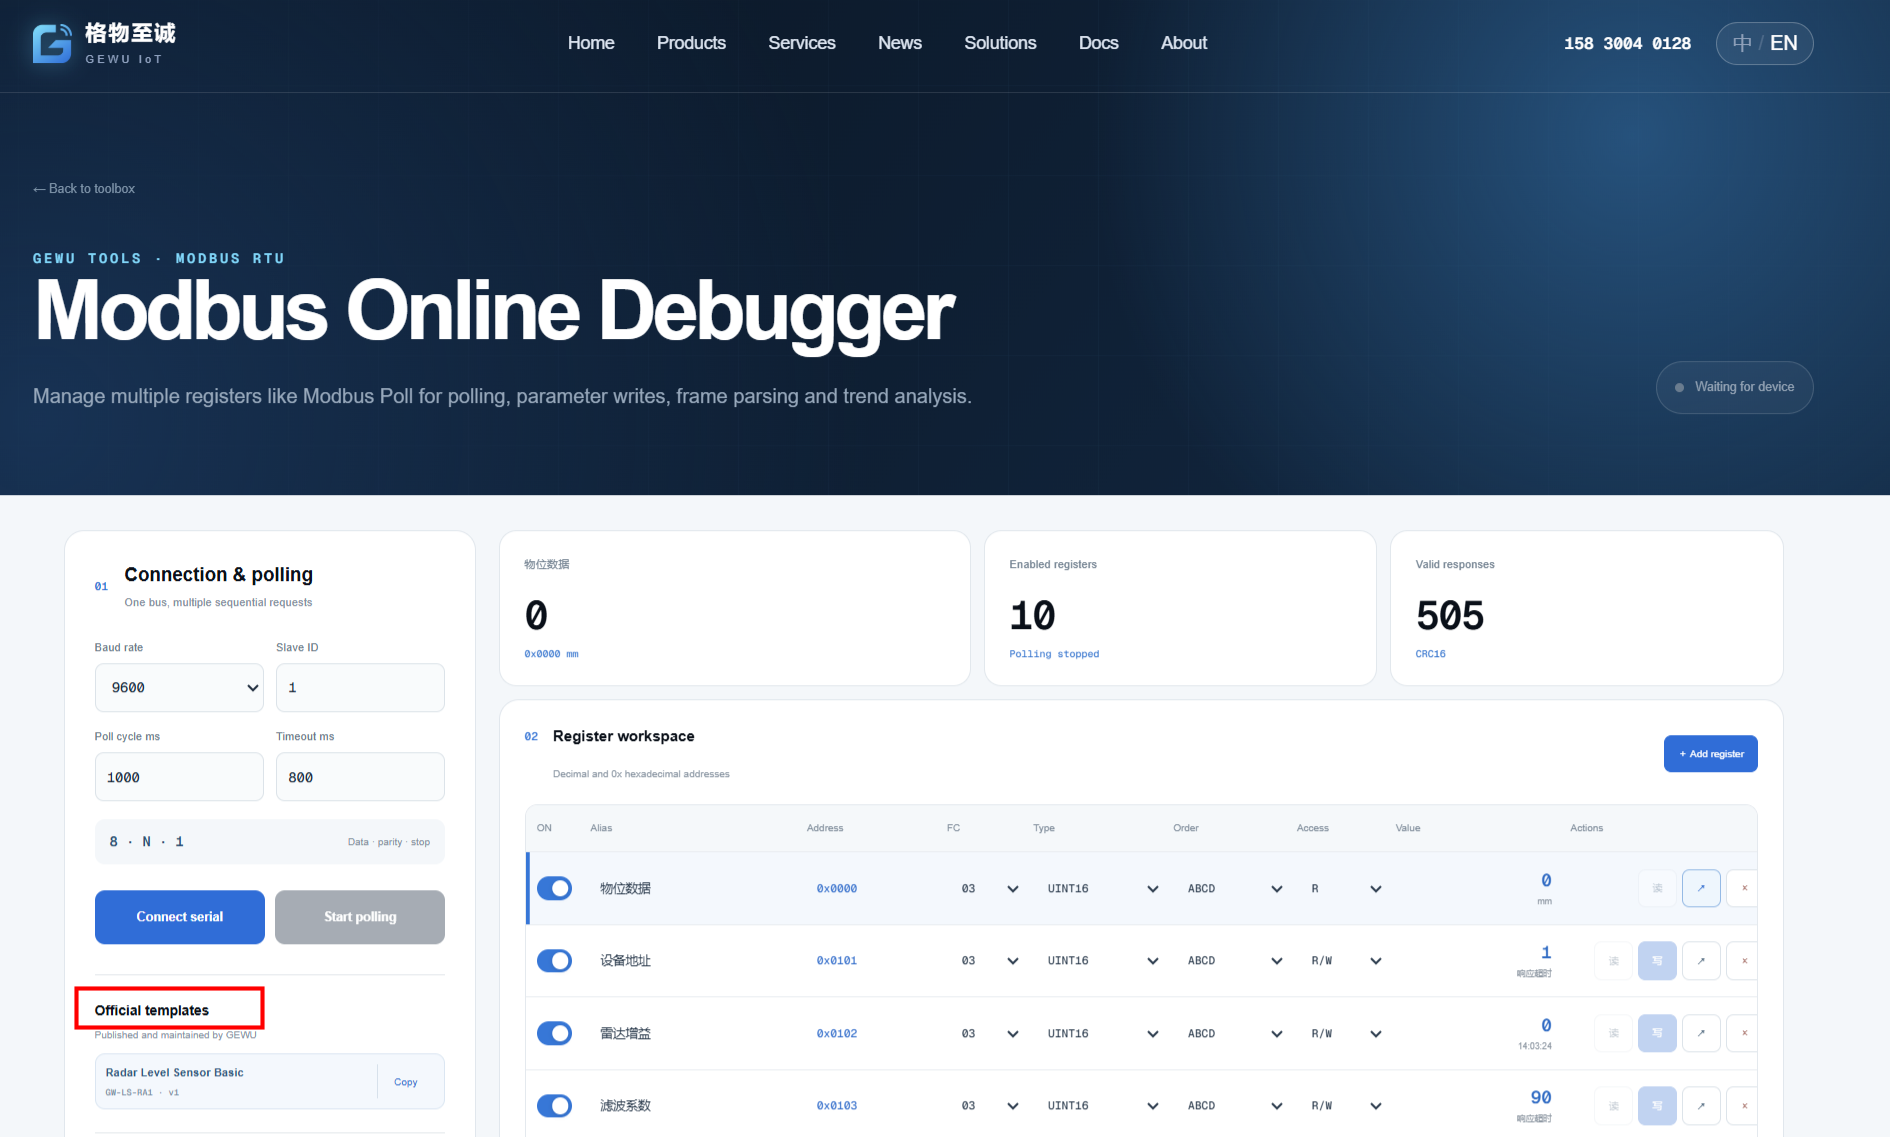
- Serial‑port parameters: 9600‑8‑N‑1.
- Click Connect Serial Port and select the serial‑port adapter connected to your computer.
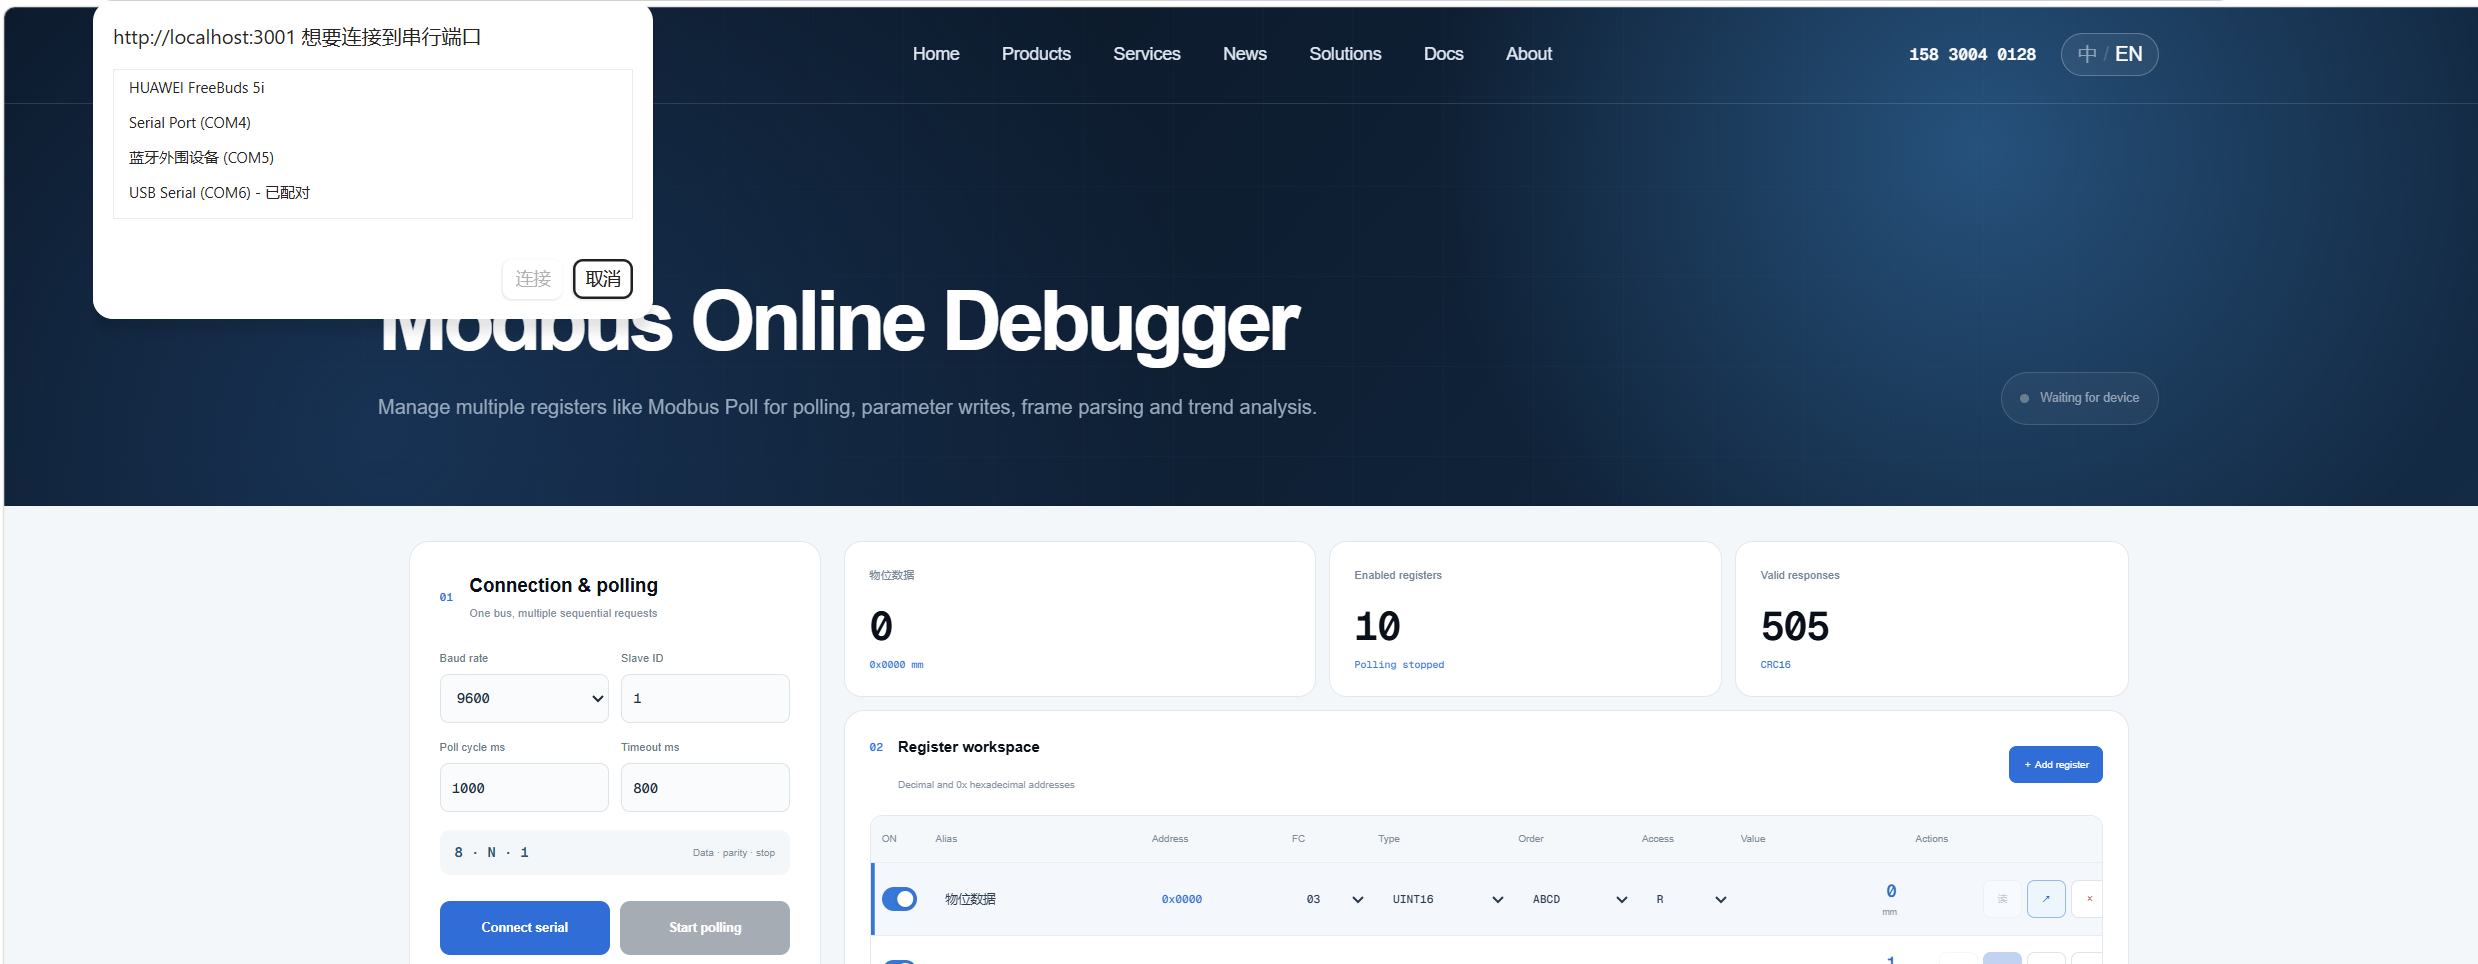
- Click Start Polling.
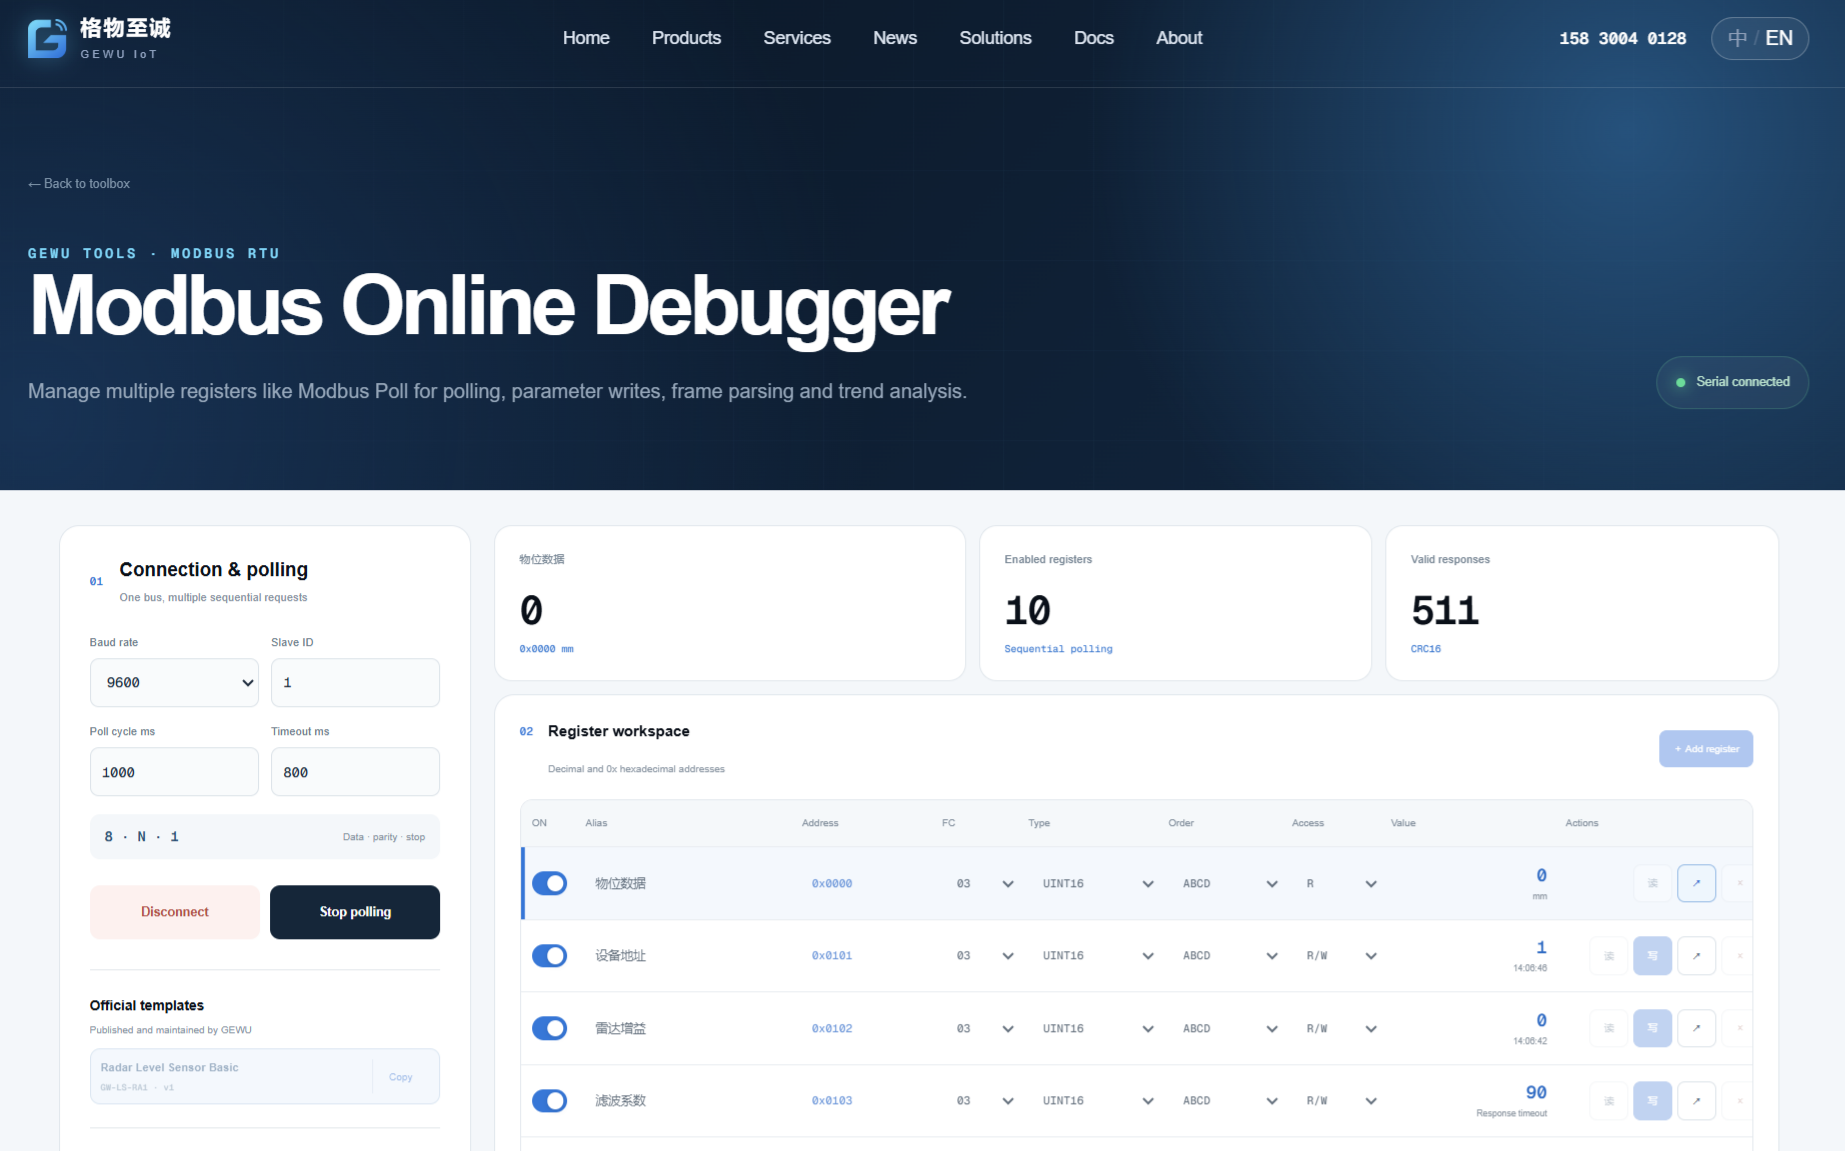
- To write parameters, navigate to the corresponding register, enter the value and click Confirm Write.
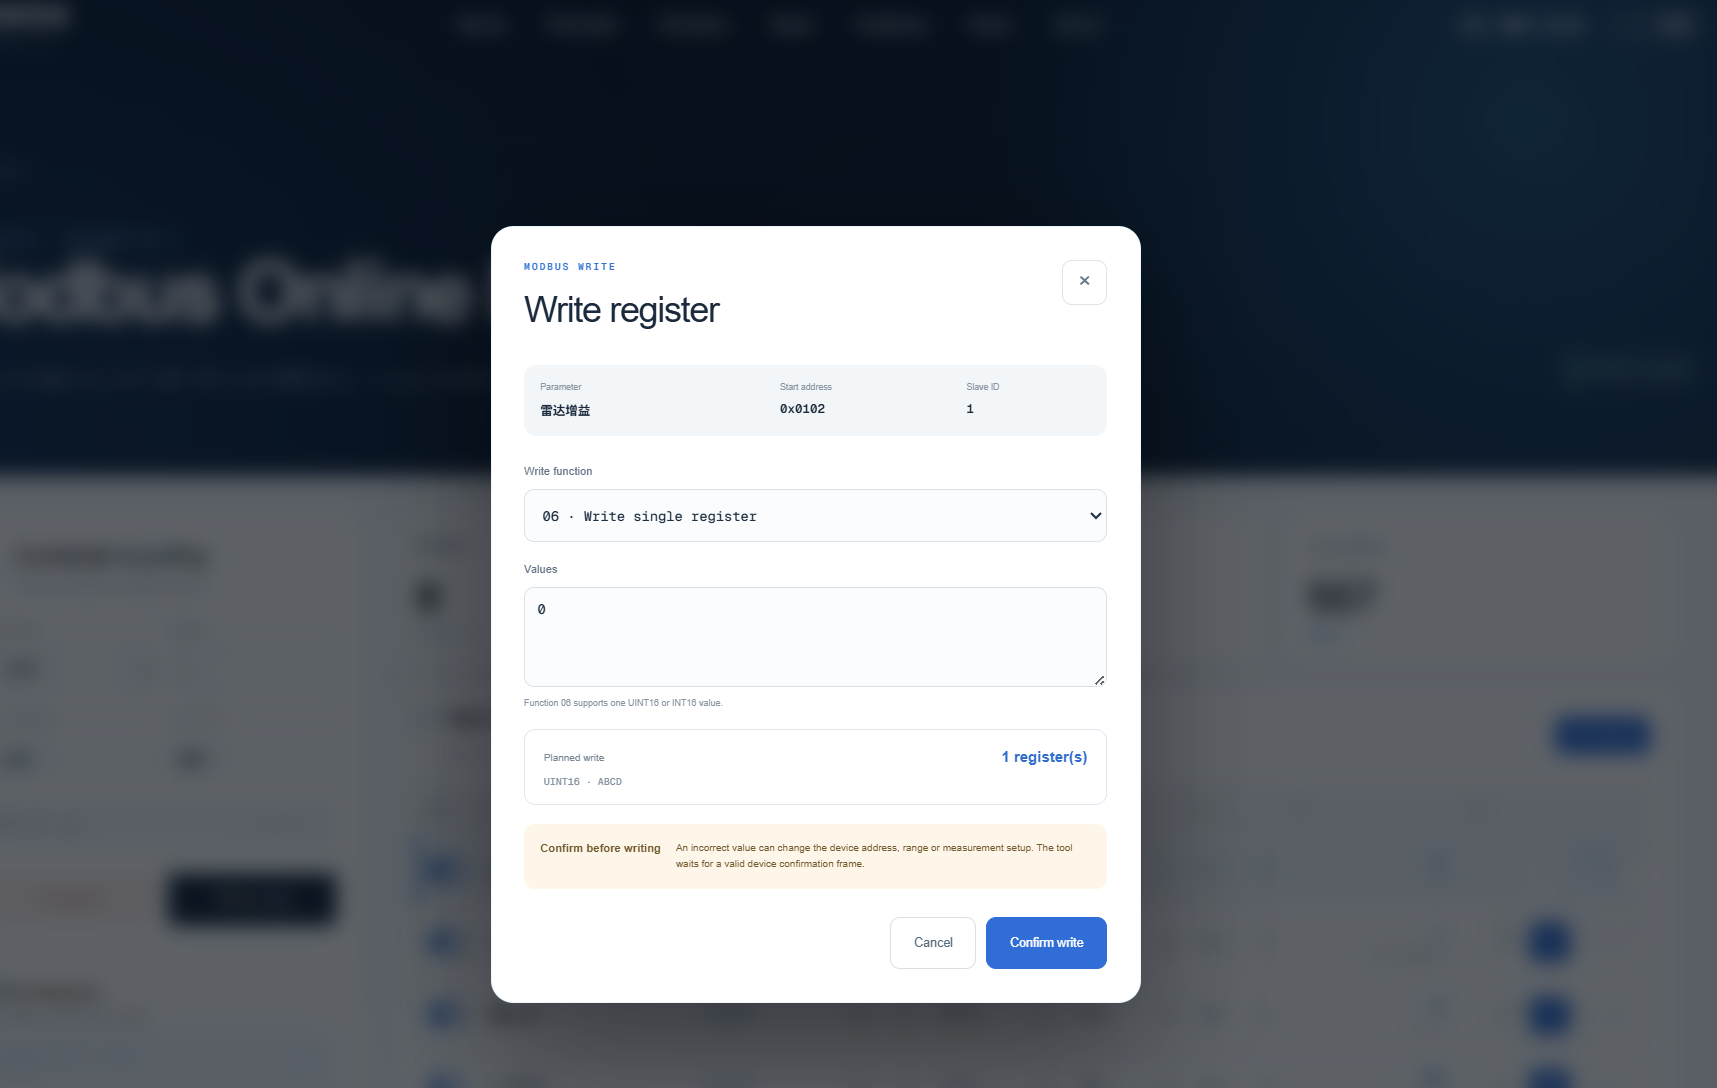
Reference‑value modification example: Current empty‑height reading = 1022 mm. Set reference value to 5000 mm; output =
5000 − 1022 = 3978 mm. Reference register address: 0x0030 (decimal 48). Write value 5000 using function code 06.Device‑address modification: while connected, write target address to register
0X03E8(decimal 1000). After address change, re‑configure and reconnect within Gewu Online Tool.
6. Wire Harness Definition
| Wire Color | Signal |
|---|---|
| Brown | VCC |
| Black | GND |
| Yellow | RS485+ |
| Blue | RS485‑ |
7. Mechanical Dimensions
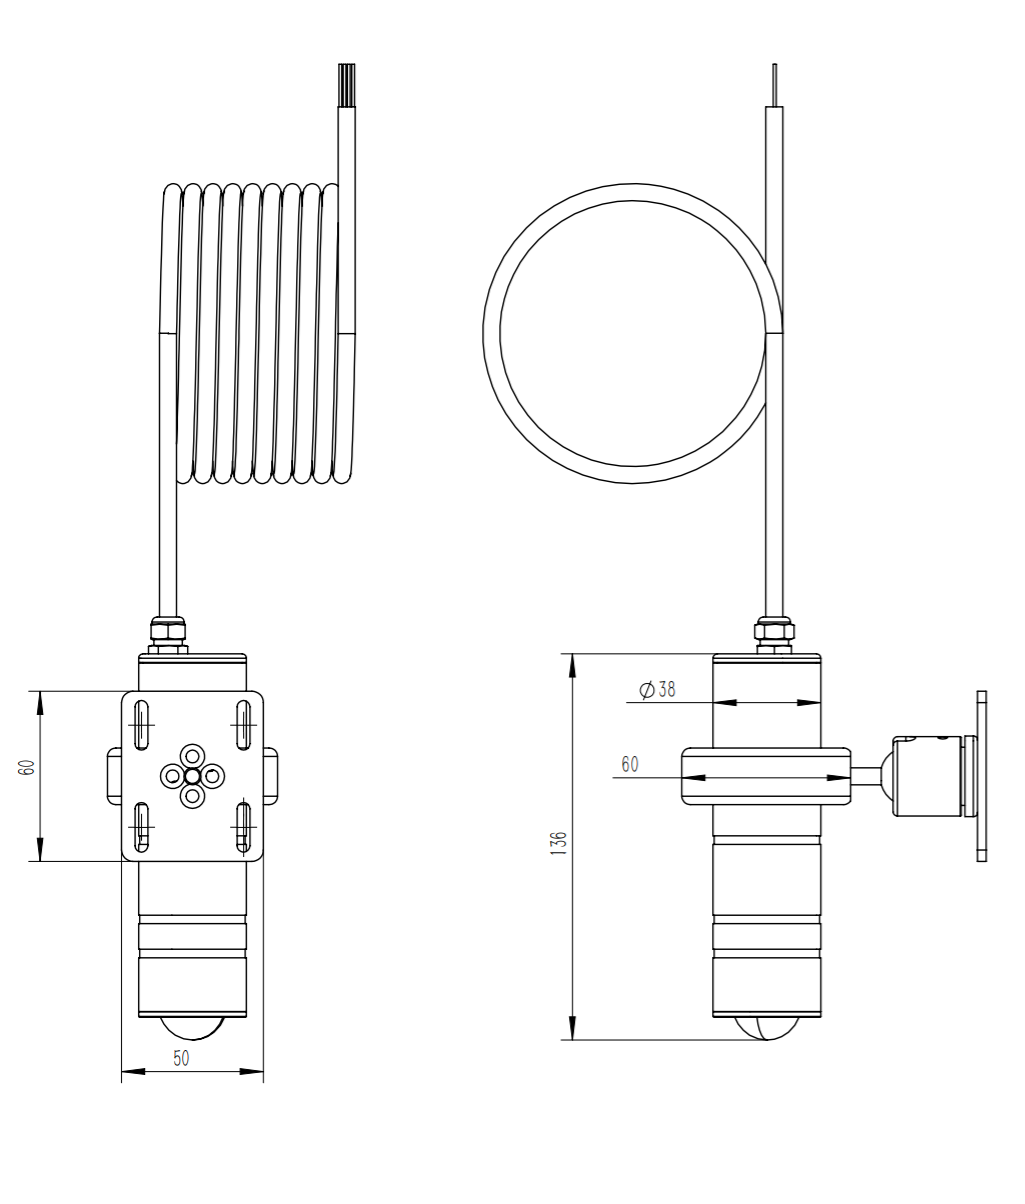
Main‑body dimension: Φ54 × 60 mm
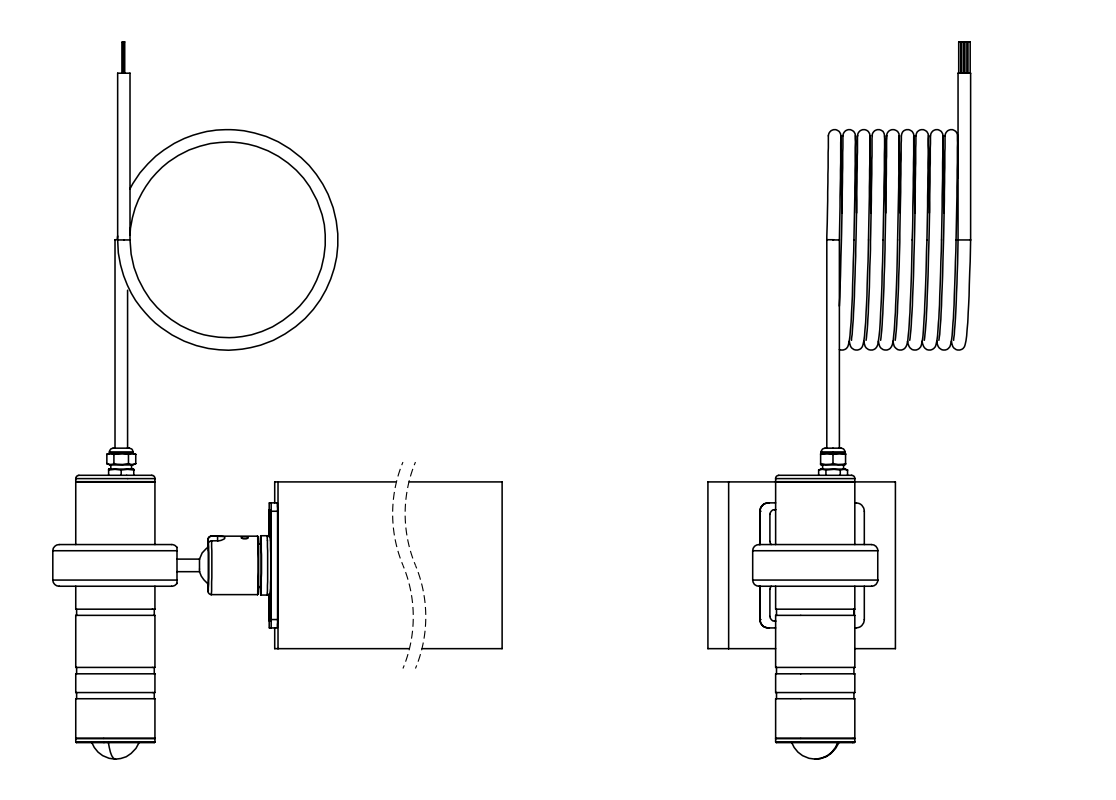
Reference mounting method:
8. Packing List
| No. | Item | Remarks |
|---|---|---|
| 1 | Sensor Main Unit | |
| 2 | Auxiliary Mounting Bracket | |
| 3 | Power‑and‑Signal Cable |
Note: Printed user manual is not supplied by default. Contact the manufacturer if a hard copy is required.
9. Precautions
Nominal measuring range of the sensor is 0.25‑12 m. Two out‑of‑range conditions may occur in field use: empty‑height less than dead‑zone; empty‑height greater than 12 m (symptoms identical to loss of valid echo, e.g. non‑vertical installation, non‑water or poor‑reflectivity target surface).
Most acquisition devices output 0 or 0xFFFF upon measurement failure. To differentiate measurement failure from out‑of‑range status, this sensor does NOT use 0 or 0xFFFF to indicate faults.
- Below dead‑zone (<0.25 m): Positive output value smaller than 0.25 m, which is invalid. This condition only occurs when the sensor is submerged; it will not appear for overhead installation.
- No valid echo (>12 m, angular misalignment, poor reflector): Negative output value. Represented as a large unsigned 16‑bit Modbus register value (near 65510), indicating invalid measurement.
Rules for host‑side judgement:
0.25 m ~ 12 m: valid measurement- Positive value <0.25 m: within dead‑zone; reading invalid
- Negative value / unsigned value equivalent to >12 m: measurement invalid; adjust mounting angle or installation position.